About the directory & our standards

Robots & toys / Supervised experiment

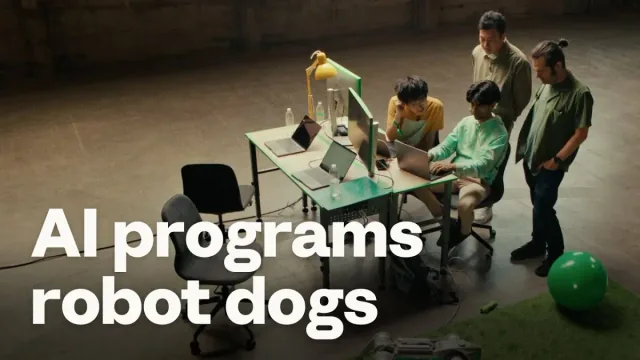
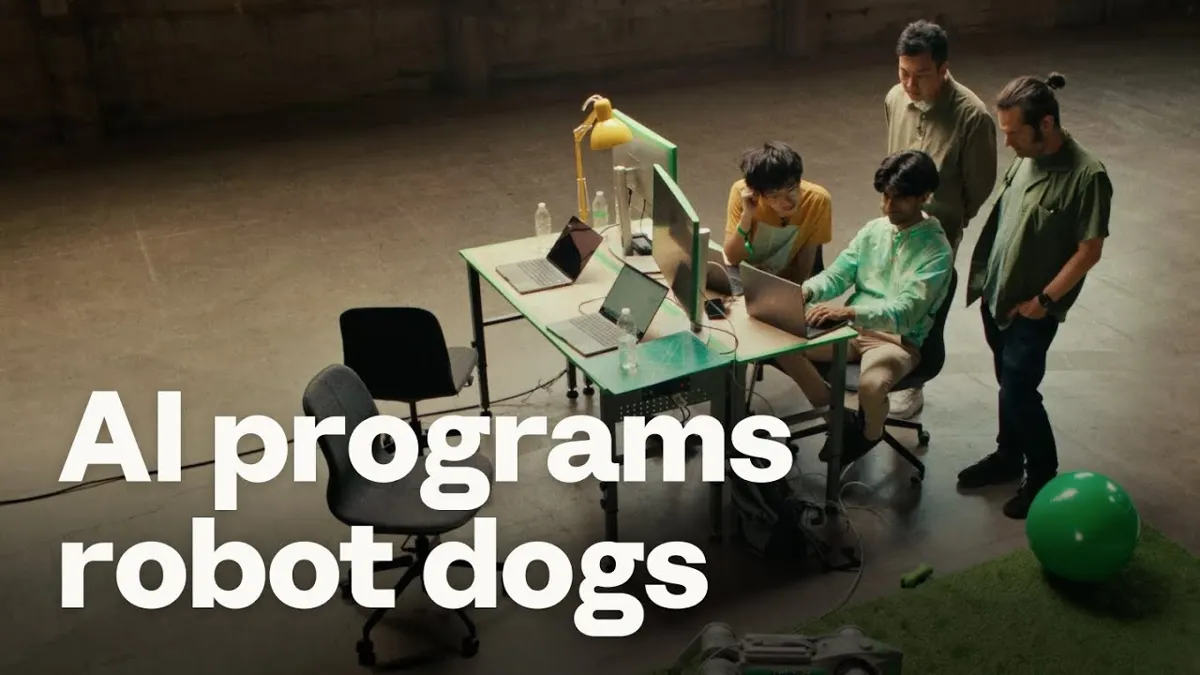
Robot dog video controller and autonomous ball approach

Custom laptop video controller, sensor access and software that locates a beach ball, approaches it and moves it; a natural-language controller was also demonstrated.

Read the original build See shopping list
Unitree Go2 robot dog in the Project Fetch experiment
Anthropic · Project Fetch

What the hardware does

Custom code uses the robot’s camera, sensors and motors to approach and move a ball.

How the agent helped

Anthropic's firsthand experiment says the robot was controlled with a program largely written by Claude and describes the code-writing, sensor and controller tasks performed by Team Claude.

Before you build

Full autonomous fetch was not completed. Keep a human supervisor and a clear operating area; collision hazards remain.

Follow the build

anthropic.com

Original build story

AI-vendor research showcase with physical demonstrations

anthropic.com
Supporting source

Anthropic · Project Fetch

Shopping list

Save as Markdown

Parts for one build. Reuse equipment you already own. Quantities are planning quantities unless the creator explicitly specifies a count; kit contents are not additional purchases.

Confirm before buying

  • Robot edition, connection stack, SDK access and full reusable code are not disclosed. This is an experiment, not a turnkey fetch kit.

Quantities are for one build. Unless marked source-specified, they are planning quantities; confirm kit contents and the chosen configuration before ordering.

  1. Qty. 1Plan / confirm
    Required

    Unitree Go2

    Robot with onboard camera and LiDAR.

    Air/Pro/EDU edition and firmware were not disclosed; SDK access must be checked before buying.

    Sources & quantity basis

    Creator source. Planning quantity for one build; check the selected configuration.

    View product

    Product family; robot edition not disclosed

  2. Qty. 1Plan / confirm
    Required

    Laptop for robot control

    Build, configure or flash the software.

    Run control code and sensor streams.

    Sources & quantity basis

    Setup requirement — check against your configuration. Planning quantity for one build; check the selected configuration.

    Use existing equipment or match the specification above. No exact purchase link verified.

  3. Qty. 1Plan / confirm
    Required

    Beach ball

    Target object.

    The experiment used a green ball for Team Claude; size not stated.

    Sources & quantity basis

    Creator source. Planning quantity for one build; check the selected configuration.

    No exact purchase link verified; confirm the model and requirements above before ordering.

  4. Qty. 1 routePlan / confirm
    Required

    Manufacturer controller or control phone

    Initial manual control and supervised operation.

    Sources & quantity basis

    Creator source. Planning quantity for one build; check the selected configuration.

    No exact purchase link verified; confirm the model and requirements above before ordering.

  5. Qty. 1Plan / confirm
    Required

    Device power supply

    Power the device.

    Use the robot’s original battery and charger; inspect a used robot’s battery.

    Sources & quantity basis

    Setup requirement — check against your configuration. Planning quantity for one build; check the selected configuration.

    Use existing equipment or match the specification above. No exact purchase link verified.

  6. Qty. Required setupPlan / confirm
    Required

    Clear test area and accessible emergency stop

    Safe supervised operation.

    No autonomous unattended operation; establish and test stop behavior before motion.

    Sources & quantity basis

    Setup requirement — check against your configuration. Planning quantity for one build; check the selected configuration.

    Use existing equipment or match the specification above. No exact purchase link verified.

Source reviewed, not assembled or hands-on tested. A working product page does not confirm stock, firmware compatibility or a complete build.

Built something with a coding agent?

Share your hardware project so others can try it.

Submit a project